Robotics software engineer in Ottawa. M.Eng. Electrical and Computer Engineering, University of Ottawa, 2024–2026. B.E. Mechatronics, Gujarat Technological University, 2019–2023. Python and C++ on Linux; ROS 2; NVIDIA Jetson; Isaac Sim and Gazebo.
- Robot interfaces
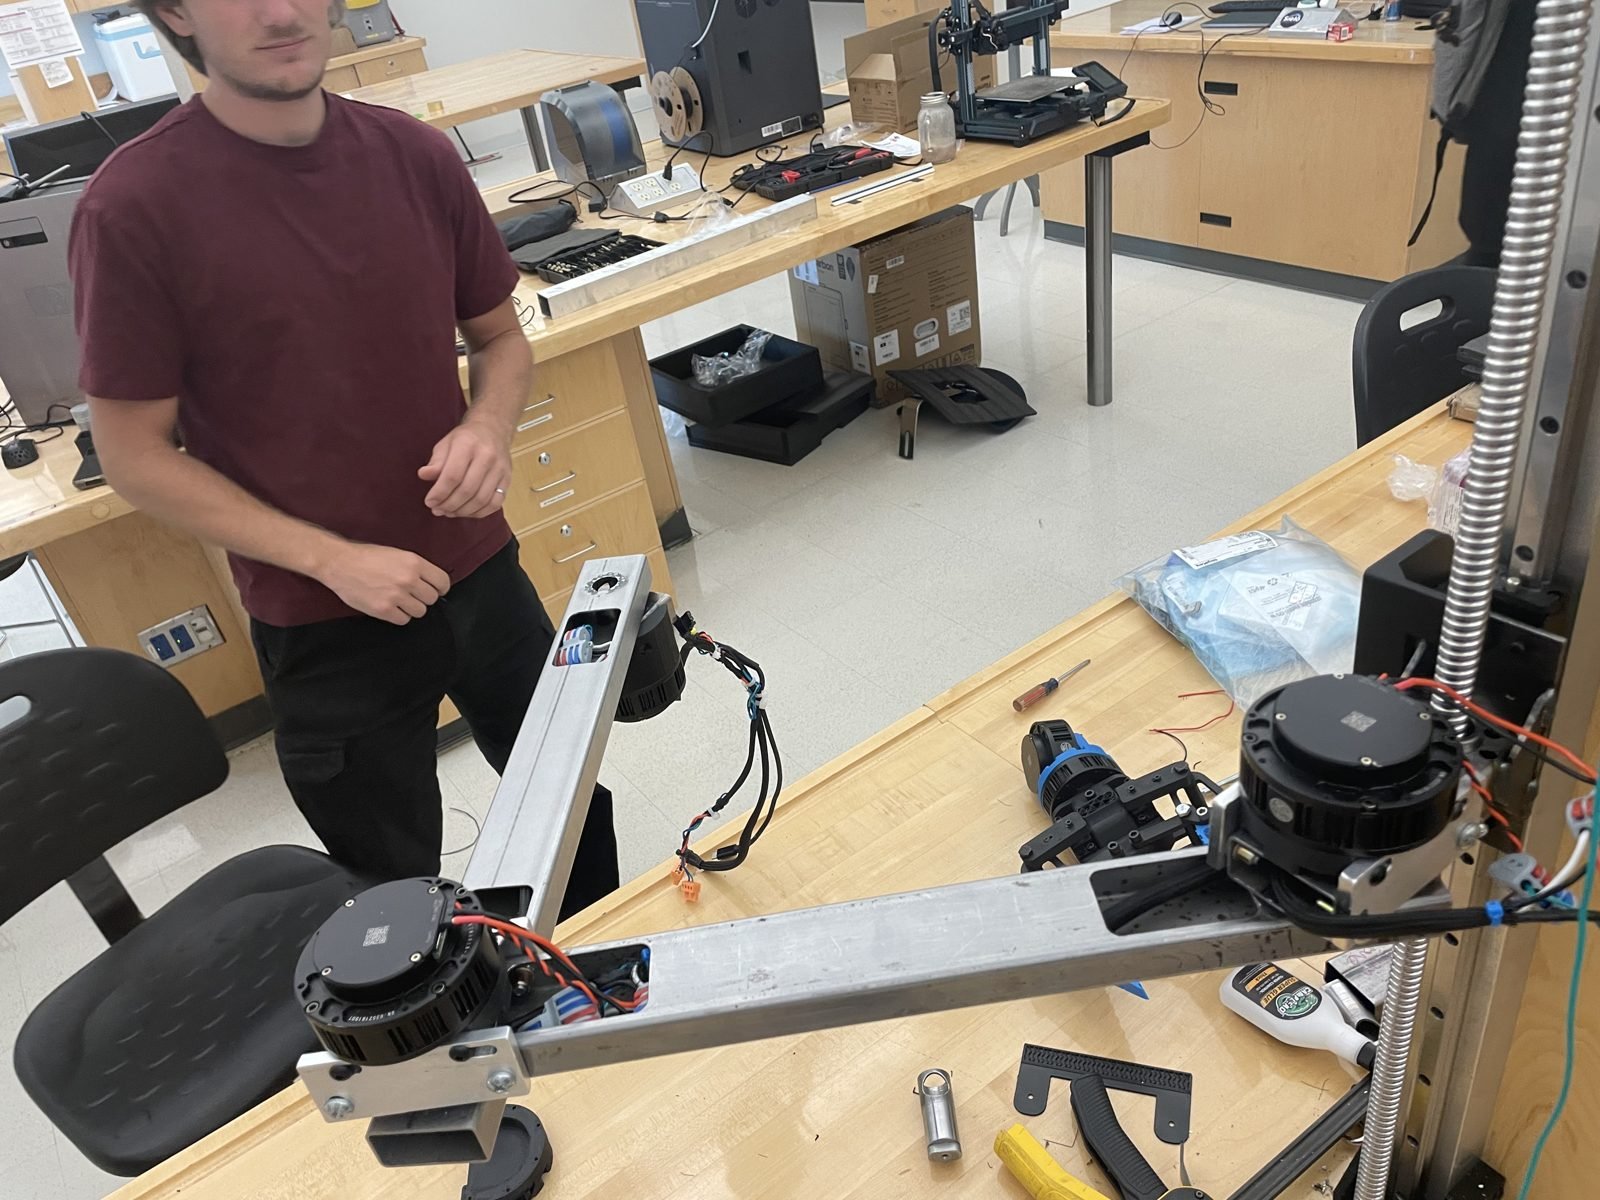
- ros2_control, CAN (SocketCAN; Robstride and Damiao MIT-mode protocols), RS232, RS485/Modbus, ESP32 firmware, real-time Linux (PREEMPT_RT, SCHED_FIFO)
- Kinematics and control
- Closed-form and numerical IK (Eigen, KDL, TRAC-IK), PD and feedforward control, gravity compensation, joint limits, MoveIt 2, TF2, URDF/Xacro/SRDF
- Teleoperation and XR
- Meta Quest 3/3S (Unity/C#, OpenXR), 6-DoF SpaceMouse, joystick arbitration, deadman gating, UDP and WebSocket clients, point-cloud streaming, record/replay
- Safety and diagnostics
- Heartbeat and watchdog failsafes, E-stop and velocity guards, torque-residual collision detection, ROS 2 diagnostics, Grafana Cloud, gtest, multimeter and serial-console debugging, ISO 14971
- Perception and learning
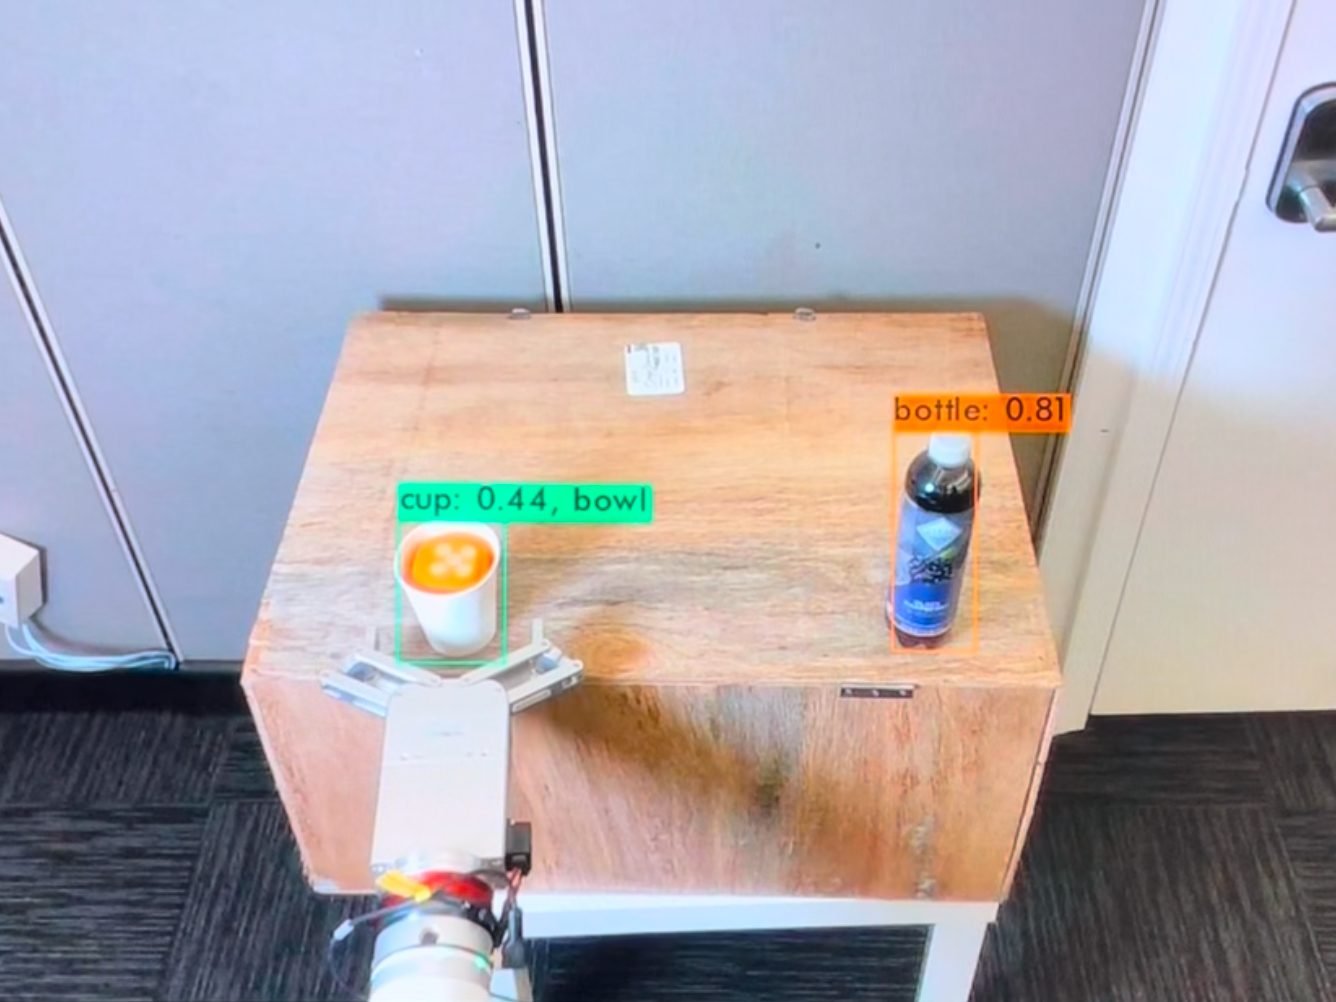
- OAK-D stereo depth (DepthAI), on-camera YOLOv8, OpenCV, camera-to-base extrinsics; LeRobot, PyTorch, Hugging Face Hub; ACT, Diffusion Policy, SmolVLA, π0, π0.5
- Data and software
- MCAP, Foxglove; Python, C++17, TypeScript/React, FastAPI, Linux, Git, GitLab CI, Docker, CMake; NVIDIA Jetson (Orin, Orin NX, Nano), Isaac Sim, Gazebo